mosi-ai.github.io
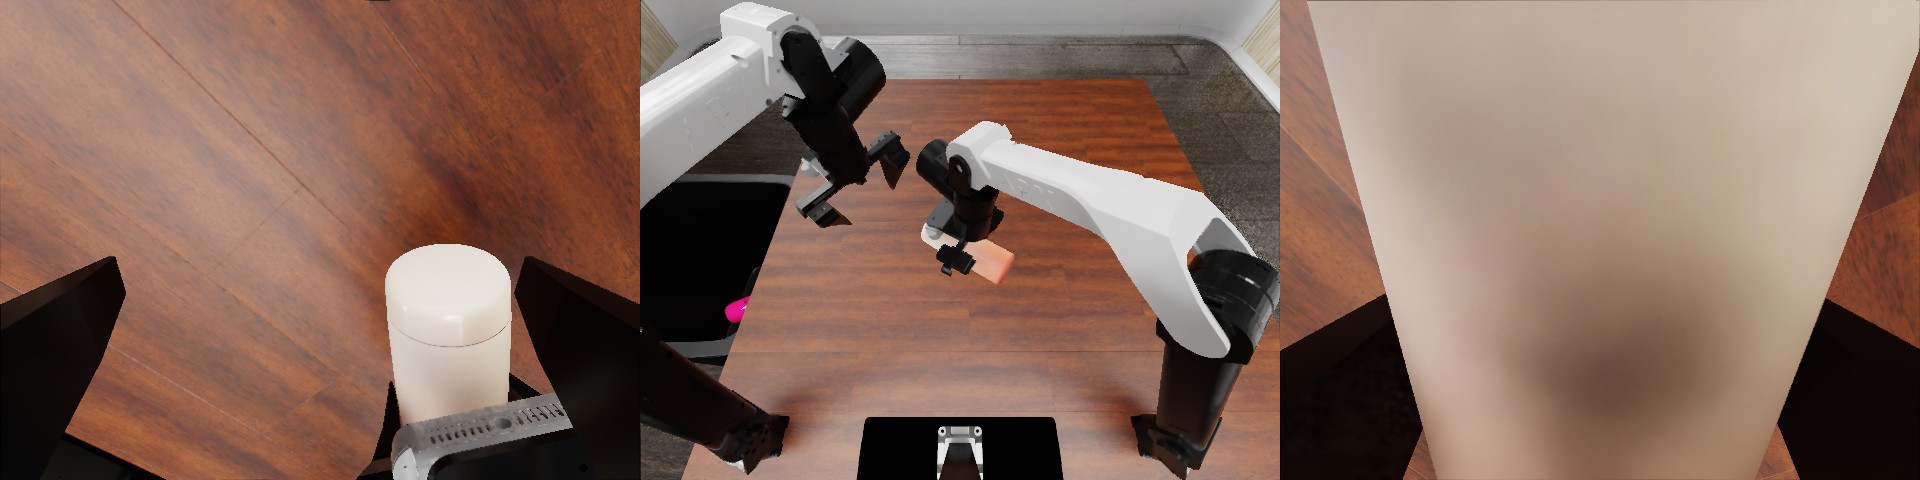
mosi-ai.github.io is Multimodal Models as Few-Shot Robot Learners. It is ranked #386 on the AI Radar, in AI research, first seen 16 h ago and shared in 1 post (1.1k views).
Embodied In-Context Learning for GPT-6 Astra Skip to main content RoboICL Sections Research preview 18 Sep 2026 Embodied In-Context Learning for GPT-6 Astra Multimodal Models as Few-Shot Robot Learners Fangcheng Liu * , Yeqing Shen * , Anda Cheng * , Weishi Mi, Chao Tang, Tingguang Li, Yong-Lu Li, Yehui Tang * Equal contribution · Corresponding author GitHub/RoboICL GPT-6 Astra achieves excellent zero-shot performance across various domains, yet remains unreliable on certain complex bimanual tasks. In this report, We study whether a general-purpose multimodal model can adapt at inference time from executable demonstrations. RoboICL places…
What people said about mosi-ai.github.io on X
过去,让机器人学会一个新任务,往往需要大量数据采集、轨迹标注和针对性的训练。 而 RoboICL 探索的是另一条路线: 不重新训练模型,而是让机器人从上下文中的示范里“现场学习”。 这里的 ICL,即 In-Context Learning(上下文学习)。 简单来说,就是: 给机器人看示范 → 理解任务规律 → 根据上下文推理 → 直接执行。 例如,在“模仿排序序列”的任务中,机器人首先观察人类或系统提供的一系列操作示范,理解不同物体之间的空间关系与操作顺序,然后尝试在新的场景中复现这一过程。 这背后的关键变化是: 机器人学习不再只是“记住训练数据”,而是开始尝试从少量示范中理解任务。…
— @qingke_ai, 16 h ago · 9 likes · see the post
Alternatives to mosi-ai.github.io
- humanbrain-pollard-h01 — We’re on a journey to advance and democratize artificial intelligence through open source and open science.
- recurrent-looped-tranformer — Official Project Page for Recurrent Looped Transformer (RLT) - yifanzhang-pro/recurrent-looped-tranformer
- 1kpapers.com — Read clear summaries of the most important AI papers from 2025–2026, organized by topic, research lab, citations,…
- research.nvidia.com — Project page
- ECDSA.fail — A benchmark arena for cracking ECDSA. Run your autoresearch harness, verify against the benchmark, and submit your…
- 2609.20800 — Join the discussion on this paper page
mosi-ai.github.io in numbers
- Rank on the AI Radar: #386 of 1321
- Shared in 1 post by 1 account: @qingke_ai
- 1.1k views on those posts
- First seen 16 h ago, last shared 16 h ago
- Pricing seen by Jev: not stated
- Market: AI research
FAQ
What is mosi-ai.github.io?
Multimodal Models as Few-Shot Robot Learners It was first shared on X 16 h ago and is ranked #386 on the AI Radar.
Is mosi-ai.github.io free?
Pricing is not stated on the page we read.
Who shared mosi-ai.github.io?
1 account on X, including @qingke_ai, in 1 post totalling 1.1k views.
Every post is read and classified by Jev (TypeSafe): what it is, which market it belongs to, and whether the link is a real tool. 31.3k posts from 4.7k X accounts over the last 14 days, 1.3k tools, 19 markets. Collected every 5 minutes, fully re-ranked every hour — last update 2026-09-19 21:10 UTC. Full method.